Chenhao Li
Embodied Intelligence
and Robot Learning.
Doctoral Fellow at ETH AI Center · Student Researcher at Google DeepMind
Hello, I’m Chenhao.
About Me#
I am currently a doctoral fellow advised by Prof. Marco Hutter and Prof. Andreas Krause at ETH AI Center, Switzerland. Since April 2026, I have been a Student Researcher in the Gemini Robotics team at Google DeepMind.
Research#
My research interests focus on algorithms that can enable autonomous agents to acquire complex behaviors through learning, especially general-purpose methods that could enable any autonomous system to learn to solve any task. This spans online learning and world modeling.
Previously#
I worked on motion representation and active learning methods at Massachusetts Institute of Technology (MIT) with Prof. Sangbae Kim, and on motion imitation from limited demonstrations and intrinsic skill exploration at Max Planck Institute for Intelligent Systems (MPI-IS) with Prof. Georg Martius.
- Reinforcement Learning
- World Models
- Vision-Language-Action Models
The latest.
Papers, talks, awards and new chapters, year by year.
2026
April 22, 2026I gave a talk on Online Reinforcement Learning at ARCAD Lab.
I had the privilege of presenting my recent work on Robotic World Model (RWM) and Uncertainty-Aware Robotic World Model (RWM-U) at the ARCAD Lab, University of Michigan. In this talk, I discussed how we can leverage model-based methods for real-world online reinforcement learning in robotics, and how uncertainty awareness can be incorporated into the training of robotic world models to enhance policy optimization in imagination.
April 10, 2026I started as a Student Researcher at Google DeepMind.
I am excited to join the Gemini Robotics team and contribute to the research in embodied intelligence and robot learning. It is a great honor to work with the brilliant minds at Google DeepMind and I look forward to the exciting research opportunities ahead!
February 21, 2026Our work was accepted to CVPR 2026.
Our work NIL: No-data Imitation Learning was accepted by IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2026. CVPR 2026 will be held in Denver, United States from Jun 03 to 07, 2026.
2025
December 6, 2025Our work received the Outstanding Paper Award at the EWM Workshop, NeurIPS, San Diego, United States.
It was announced during Conference on Neural Information Processing Systems (NeurIPS) 2025 in San Diego, United States that our work Robotic World Model: A Neural Network Simulator for Robust Policy Optimization in Robotics received the outstanding paper award at the Embodied World Models for Decision Making Workshop. As one of fifty accepted papers, our work received great acknowledgment from the community.
October 2, 2025Our workshop at the 2025 International Conference on Humanoid Robots concluded with great success.
Together with Julian Eßer, Gabe Margolis, and Huazhe Xu, I had the privilege of organizing the Sim-to-Real Transfer for Humanoid Robots Workshop at the 2025 International Conference on Humanoid Robots in Seoul, South Korea. The workshop brought together leading researchers and practitioners to discuss the latest advances and challenges in bridging the gap between simulation and real-world humanoid control.
September 17, 2025I gave a talk on Learning from Demonstrations at MyoLab.
In this talk, I had the privilege of presenting a comprehensive overview of my experience in the field of Learning from Demonstrations. I discussed the evolution of LfD techniques from feature-based methods to modern generative approaches such as GAN-based learning, and highlighted how these methods have shaped current trends in both robotics and character animation.
August 8, 2025Two papers were accepted to CoRL 2025.
Our papers Motion Priors Reimagined: Adapting Flat-Terrain Skills for Complex Quadruped Mobility and Constrained Style Learning from Imperfect Demonstrations under Task Optimality were accepted by Conference on Robot Learning (CoRL) 2025. CoRL 2025 will be held in Seoul, South Korea from September 27 to 30, 2025.
July 15, 2025We published a survey on Learning from Demonstrations.
While learning from demonstrations has become a widely adopted strategy, many practitioners choose methods based on precedent or anecdotal success rather than a systematic understanding of the algorithmic factors driving performance. Drawing on our extensive experience in the field, we developed Feature-Based vs. GAN-Based Imitation: When and Why, a comprehensive survey designed to provide structured guidance and serve as a practical resource for the community.
January 27, 2025Our work was accepted to ICRA 2025.
Our work DFM: Deep Fourier Mimic for Expressive Dance Motion Learning was accepted by IEEE International Conference on Robotics and Automation (ICRA) 2025. ICRA 2025 will be held in Atlanta, United States from May 19 to 23, 2025.
2024
October 8, 2024Our work was accepted to NeurIPS 2024.
Our work Dataset and Lessons Learned from the 2024 SaTML LLM Capture-the-Flag Competition was accepted by The Thirty-Eighth Annual Conference on Neural Information Processing Systems (NeurIPS) 2024. NeurIPS 2024 will be held in Vancouver, Canada from Dec 10 to 15, 2024.
April 5, 2024I received the ETH Medal at my master's graduation ceremony.
I feel extremely honored to receive the ETH Medal at my master's graduation ceremony at ETH Zurich. The ETH Medal is awarded to students with outstanding master's and doctoral theses. I am deeply grateful and view this as recognition and acknowledgment of my work during my master's studies. I would like to express my sincere gratitude to my advisors Prof. Georg Martius, Prof. Sangbae Kim, and especially Prof. Marco Hutter for their guidance and support.
April 5, 2024An unforgettable reunion of friends at my master's graduation ceremony.
The graduation ceremony officially concludes my master's studies at ETH Zurich. It was an unforgettable reunion of friends who shared this great journey with me. I am grateful for the opportunity to have met so many wonderful people during my studies. I am excited to see where our paths will lead us next.
March 13, 2024Our work was accepted to ICLR 2024 Generative Models for Decision Making workshop.
Our work FLD: Fourier Latent Dynamics for Structured Motion Representation and Learning was accepted to the Generative Models for Decision Making (GenAI4DM) workshop at The Twelfth International Conference on Learning Representations (ICLR). This workshop aims to bring together researchers and practitioners from the fields of generative AI and decision making to explore the latest advances, methodologies, and applications.
March 4, 2024Our defense won second prize in the LLM CTF competition at IEEE SaTML 2024.
Our team won second prize with our Llama-2-70b-chat defense in the Large Language Models Capture-the-Flag (LLM CTF) competition at 2024 IEEE Conference on Secure and Trustworthy Machine Learning (SaTML). In this competition, participants assume the roles of defenders who craft prompts and filters to instruct an LLM to keep a secret, aiming to prevent its discovery in a conversation.
January 29, 2024Our work was accepted to ICRA 2024.
Our work Learning Diverse Skills for Local Navigation under Multi-constraint Optimality was accepted by IEEE International Conference on Robotics and Automation (ICRA) 2024. ICRA 2024 will be held in Yokohama, Japan from May 13 to 17, 2024.
January 16, 2024Our work was accepted to ICLR 2024 for a spotlight presentation.
Our work FLD: Fourier Latent Dynamics for Structured Motion Representation and Learning was accepted by The Twelfth International Conference on Learning Representations (ICLR) for a spotlight presentation. ICLR 2024 will be held in Vienna, Austria from May 7 to 11, 2024.
2023
November 1, 2023I started my Ph.D. journey as a doctoral fellow at ETH AI Center.
I am excited to share that I started my Ph.D. program as a doctoral fellow at ETH AI Center at ETH Zurich, Switzerland. I am honored to be co-supervised by Prof. Andreas Krause and Prof. Marco Hutter.
October 3, 2023I finished my visit at the Biomimetic Robotics Lab at MIT.
I am thrilled to wrap up my visit with the talented team at the Biomimetic Robotics Lab at Massachusetts Institute of Technology (MIT), Cambridge, United States. It has been an invaluable experience, collaborating on cutting-edge legged robotics. I am eager to see our collective efforts make a meaningful impact on the robot learning community!
June 3, 2023Great time at ICRA 2023.
It was wonderful to have met my old and new friends during IEEE International Conference on Robotics and Automation (ICRA) 2023 in London, United Kingdom. I am excited to see that our work Versatile Skill Control via Self-supervised Adversarial Imitation of Unlabeled Mixed Motions has been acknowledged by the greatest roboticists in the field. Thanks to the team Sebastian Blaes, Pavel Kolev, Marin Vlastelica, Jonas Frey and Georg Martius, who made this work possible.
April 27, 2023Our work was accepted to ICRA 2023 Agile Movements workshop.
Our work Versatile Skill Control via Self-supervised Adversarial Imitation of Unlabeled Mixed Motions was accepted to the Agile Movements: Animal Behavior, Biomechanics, and Robot Devices workshop at IEEE International Conference on Robotics and Automation (ICRA) 2023. This workshop invites researchers to identify the challenges and opportunities of understanding and improving robotic agility from a diverse range of areas, including biology, biomechanics, mechanism design, and control.
March 2, 2023I received the ETH AI Center Doctoral Fellowship.
I am excited to share that I received the ETH AI Center Doctoral Fellowship at ETH Zurich, Switzerland. The ETH AI Center Fellowship is awarded to doctoral students, who are co-supervised by two faculty members from different departments within ETH Zurich, thus fostering a culture of interdisciplinary exchange and collaboration. I am extremely honored to receive this offer from Prof. Andreas Krause and Prof. Marco Hutter.
February 16, 2023Our work on Solo robots at MPI-IS was reported by a German TV network.
My work on Solo robots during my internship at the Max Planck Institute for Intelligent Systems was covered in NANO on 3sat. In the coverage, Prof. Georg Martius explained how autonomous learning systems can obtain extraordinary intelligence from interactions with the environment.
February 4, 2023I received admission offers to the Ph.D. programs at MIT EECS and other prominent institutes.
I am excited to share that I received admission offers to the Ph.D. programs at the departments of Electrical Engineering and Computer Science (EECS) and Mechanical Engineering (MechE) at Massachusetts Institute of Technology (MIT), Cambridge, United States. I was also lucky to be admitted to the Robotics Institute at Carnegie Mellon University (CMU), Pittsburgh, United States. I am honored and view these as recognition and acknowledgment of my work during my master's studies.
January 16, 2023Our work was accepted to ICRA 2023.
Our work Versatile Skill Control via Self-supervised Adversarial Imitation of Unlabeled Mixed Motions was accepted by IEEE International Conference on Robotics and Automation (ICRA). ICRA 2023 will be held in London, United Kingdom from May 29 to June 2, 2023.
January 9, 2023I started my visit at Biomimetic Robotics Lab at MIT.
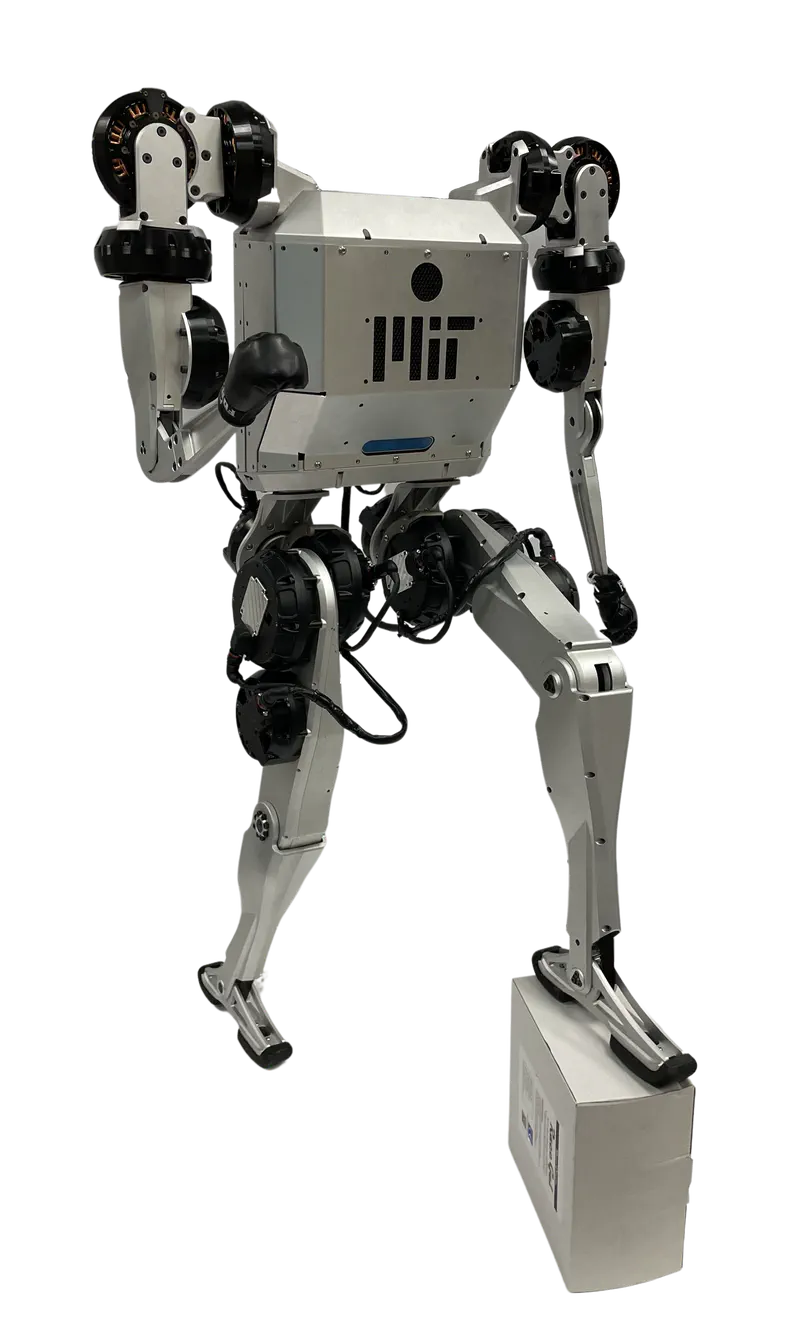
Starting from January, I am honored to work with Prof. Sangbae Kim at Biomimetic Robotics Lab at Massachusetts Institute of Technology (MIT), Cambridge, United States. My main research topic focuses on developing latent skill representation for the MIT Humanoid robot. I am happy to collaborate with Steve Heim and Elijah Stanger-Jones on this exciting topic.
2022
December 19, 2022Great time at CoRL 2022 and satisfying results for my first publication.
It was wonderful to have met all the great names and my future collaborators and advisors during Conference on Robot Learning (CoRL) 2022 in Auckland, New Zealand. I am excited to see that our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations has been acknowledged by the greatest roboticists in the field and was named a finalist for the Best Paper Award. Thanks to the team Marin Vlastelica, Sebastian Blaes, Jonas Frey, Felix Grimminger and Georg Martius, who made this achievement possible.
December 16, 2022Our work was named a finalist for the Best Paper Award at CoRL 2022, Auckland, New Zealand.
It was announced during Conference on Robot Learning (CoRL) 2022 in Auckland, New Zealand that our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was named a finalist for the Best Paper Award. As one of the three nominated papers, our work received great acknowledgment from the community.
December 2, 2022Our work was presented to the Machines in Motion Laboratory, New York University, United States.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was presented to the scholars at the Machines in Motion Laboratory led by Prof. Ludovic Righetti at New York University. The Machines in Motion Laboratory focuses on understanding the fundamental principles for robot locomotion and manipulation that will endow robots with the robustness and adaptability necessary to efficiently and autonomously act in an unknown and changing environment.
November 25, 2022I will join the Biomimetic Robotics Lab at MIT for my master thesis.
I am glad to share that I will join the Biomimetic Robotics Lab led by Prof. Sangbae Kim at Massachusetts Institute of Technology (MIT) to complete my master thesis later this year. The Biomimetic Robotics Lab focuses on designing and controlling robots using insights taken from the natural world. I will be working with the MIT Humanoid on human demonstration imitation.
November 22, 2022Our work was accepted to CoRL 2022 Learning for Agile Robotics workshop.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was accepted to the Learning for Agile Robotics workshop at Conference on Robot Learning (CoRL) 2022. This workshop invites researchers working on making agile robots. The goals include fostering collaboration, understanding the current limitations and inefficiencies, learning common ideas on modern ML based approaches, etc.
November 21, 2022Our work made it into the Video Friday collection at IEEE Spectrum again.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was covered by Video Friday collection at IEEE Spectrum. Video Friday is a weekly selection of state-of-the-art robotics videos, collected by scholars at IEEE Spectrum Robotics. This time, our overview video was selected and well acknowledged.
September 15, 2022Our work was submitted to IEEE International Conference on Robotics and Automation (ICRA) 2023.
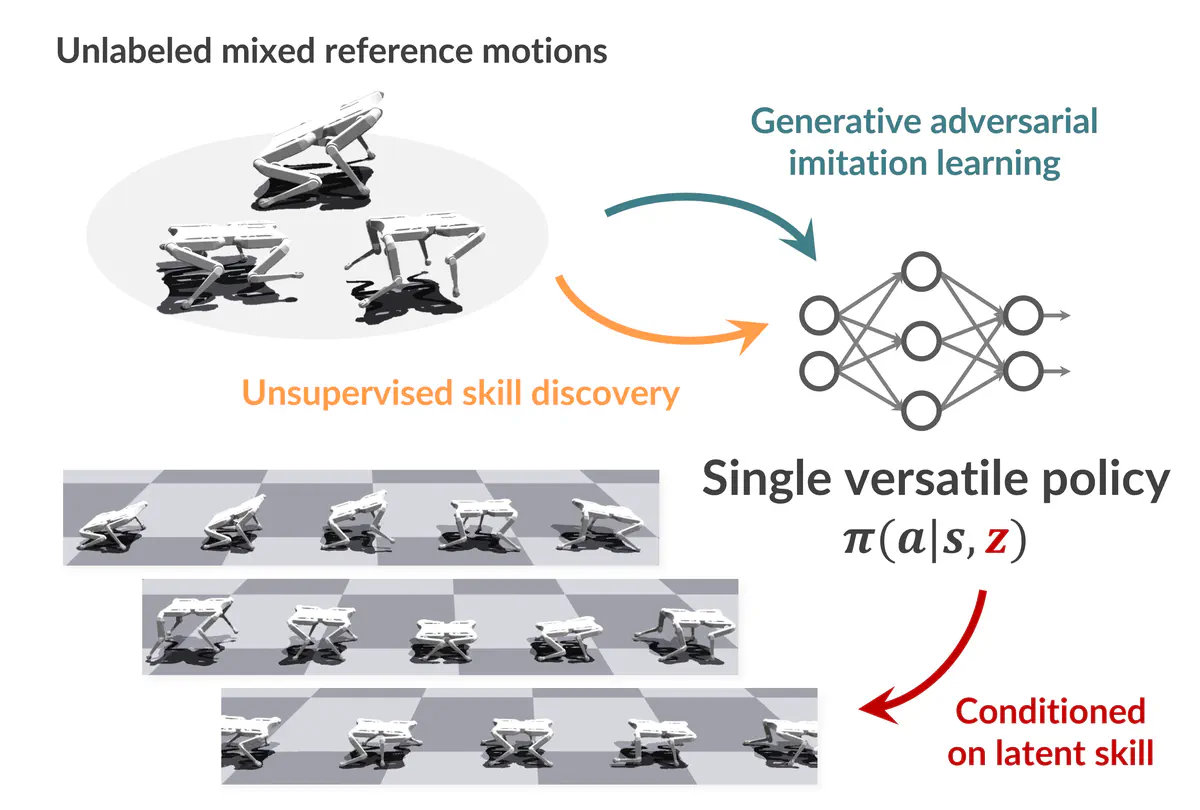
During the second three months of my internship, I accomplished the work Versatile Skill Control via Self-supervised Adversarial Imitation of Unlabeled Mixed Motions under the guidance of Sebastian Blaes, Pavel Kolev, Marin Vlastelica, Jonas Frey and Prof. Georg Martius. In this work, Solo obtained diverse skills by imitating unlabeled, mixed reference motions.
September 10, 2022Our work was accepted to CoRL 2022 for an oral presentation with a Best Paper Award nomination.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was accepted by Conference on Robot Learning (CoRL) 2022 for an oral presentation with a Best Paper Award nomination. CoRL 2022 will be held in Auckland, New Zealand from December 14 to 18, 2022.
August 10, 2022Our work was presented to the Robotic Systems Lab, ETH Zurich, Switzerland.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was presented to the scholars at the Robotic Systems Lab (RSL), ETH Zurich during the research presentation. In this weekly event, internal and external researchers are invited to present their state-of-the-art discoveries in fields including robotic system integration and control methods.
July 2, 2022Our work was presented to the public at the Science & Innovation Days, Tübingen.
The experiments of our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations were presented to the public at the Tübingen Science & Innovation Days. In this event, research institutes including the Max Planck Institute for Intelligent Systems open their doors to the interested public and present their research.
July 1, 2022Our work made it into the Video Friday collection at IEEE Spectrum.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was covered by Video Friday collection at IEEE Spectrum. Video Friday is a weekly selection of state-of-the-art robotics videos, collected by scholars at IEEE Spectrum Robotics. Among our selected videos, SOLOBACKFLIP gained particular popularity.
June 29, 2022Our work was presented to scholars from the International Max Planck Research School for Intelligent Systems.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was presented to the evaluation committee and Ph.D. scholars from the International Max Planck Research School for Intelligent Systems (IMPRS) during the on-site evaluation.
June 15, 2022Our work was submitted to Conference on Robot Learning (CoRL) 2022.
During the first three months of my internship, I accomplished the work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations under the guidance of Marin Vlastelica, Sebastian Blaes, Jonas Frey, Felix Grimminger and Prof. Georg Martius. In this work, Solo developed highly dynamic skills by imitating rough, partial, human-demonstrated reference motions.
April 1, 2022I started my internship at Autonomous Learning Group at Max Planck Institute for Intelligent Systems.
Starting from April, I am honored to work with Prof. Georg Martius at Autonomous Learning Group at Max Planck Institute for Intelligent Systems (MPI-IS), Tübingen, Germany. My main research topic focuses on agile skill development and style diversification for Solo robot. This work is closely collaborated with Robotic Systems Lab (RSL), ETH Zurich, Switzerland.
March 30, 2022My semester project at Robotic Systems Lab (RSL) finished with successful policy deployment on the real system.
By employing a novel compositional control structure, ANYmal learned to achieve full-pose trajectory tracking in a global coordinate system. A hierarchical system pipeline was introduced, where the high-level policy processes global target information and outputs low-level composition signals and commands with trivial regularization.
2021
October 1, 2021I started my semester project at Robotic Systems Lab (RSL), ETH Zurich, Switzerland.
From October, I am honored to work on a semester project on the skill integration for ANYmal with hierarchical reinforcement learning at Robotic Systems Lab (RSL) directed by Prof. Marco Hutter. The main research topic focuses on extending locomotion and manipulation capabilities for legged systems by leveraging appropriate combination of acquired skills. This project is mainly supervised by Yuntao Ma, Takahiro Miki and Mayank Mittal.
September 1, 2021I started my teaching assistant position for Linear & Combinatorial Optimization at ETH Zurich, Switzerland.
After having achieved top grades in the course Linear & Combinatorial Optimization (L&CO, 11 ECTS) instructed by Prof. Rico Zenklusen at ETH Zurich last semester, I was honored to take a teaching assistant position for the new semester. Among my responsibilities, I enjoyed delivering lectures the most.
July 9, 2021Wonderful week at ETH Robotics Summer School in Wangen an der Aare, Switzerland.
From July 2 to 9, I was honored to participate in the ETH Robotics Summer School directed by ETH RobotX initiative. During this event, a broad scope of components of autonomous mobile robots including state estimation, trajectory optimization, environment mapping, path planning, and artifact detection were introduced and implemented on a wheeled platform, SuperMegaBot. On the last day, we successfully completed an autonomous rescue challenge at the test site.
2020
September 1, 2020I started my master's program in Robotics, Systems and Control at ETH Zurich, Switzerland.
After receiving offers from top-class universities including University of California, Los Angeles (UCLA), Johns Hopkins University (JHU), École polytechnique fédérale de Lausanne (EPFL), Imperial College London, etc, I decided to pursue my future endeavors in Robotics, Systems and Control under the guidance of Prof. Marco Hutter at ETH Zurich, Switzerland.
June 15, 2020I was awarded Excellent Graduate of Shanghai.
Together with 11 other students from the School of Mechanical Engineering, it was my honor to be granted the highest honor for all undergraduates of all majors from more than ten universities in Shanghai this year.
February 1, 2020My research project at Biorobotics Laboratory (BioRob) finished with successful hardware test.
My work on Analysis, Design and Implementation of a Bio-inspired Passive Tail for Amphibious Robots concluded with a novel development of an appropriate chordwise stiffness distribution along a bio-inspired tail for AgnathaX which maximizes the propulsion generated under a combined movement of both passive heaving and pitching.
2019
September 1, 2019I started my research project at Biorobotics Laboratory (BioRob) at École polytechnique fédérale de Lausanne (EPFL), Switzerland.
I am honored to work as a research assistant on the design of a bio-inspired passive tail for amphibious robots at Biorobotics Laboratory (BioRob) directed by Prof. Auke Ijspeert during the last year of my bachelor's study. This project is mainly supervised by Laura Paez.
2018
November 16, 2018I was awarded my second National Scholarship for my study at Tongji University, Shanghai, China.
The Ministry of Education of China funded the China National Scholarship to award outstanding full-time undergraduates for their excellent academic records. Being among the top 1% of the students of the same year again, I am honored to receive this award a second time.
October 1, 2018I finished my research internship at Advanced Multifunctional and Multiphysics Metamaterials Lab (AM3L) of the Department of Bioresource Engineering of McGill University, Montréal, Canada.
From July to October, I was honored to be selected for the Mitacs Globalink Research Internship program and to work on Design and 3D Printing of Lightweight Advanced Energy Harvesters Made of Smart Materials under the supervision of Prof. Abdolhamid Akbarzadeh. The research was devoted to reinforcing mechanical properties of 3D printing materials by combining pulverized wood particles with melted polymer through a novel process of extrusion.
April 1, 2018I was awarded Meritorious Winner in 2018 Mathematical Contest in Modeling.
I am honored to receive my first international award in Mathematics.
2016
November 16, 2016I was awarded my first National Scholarship for my study at Tongji University, Shanghai, China.
The Ministry of Education of China funded the China National Scholarship to award outstanding full-time undergraduates for their excellent academic records. Being among the top 1% of the students of the same year, I am honored to receive this award.
2026
I gave a talk on Online Reinforcement Learning at ARCAD Lab.
I had the privilege of presenting my recent work on Robotic World Model (RWM) and Uncertainty-Aware Robotic World Model (RWM-U) at the ARCAD Lab, University of Michigan. In this talk, I discussed how we can leverage model-based methods for real-world online reinforcement learning in robotics, and how uncertainty awareness can be incorporated into the training of robotic world models to enhance policy optimization in imagination.I started as a Student Researcher at Google DeepMind.Milestone
I am excited to join the Gemini Robotics team and contribute to the research in embodied intelligence and robot learning. It is a great honor to work with the brilliant minds at Google DeepMind and I look forward to the exciting research opportunities ahead!Our work was accepted to CVPR 2026.Milestone
Our work NIL: No-data Imitation Learning was accepted by IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2026. CVPR 2026 will be held in Denver, United States from Jun 03 to 07, 2026.
2025
Our work received the Outstanding Paper Award at the EWM Workshop, NeurIPS, San Diego, United States.Milestone
It was announced during Conference on Neural Information Processing Systems (NeurIPS) 2025 in San Diego, United States that our work Robotic World Model: A Neural Network Simulator for Robust Policy Optimization in Robotics received the outstanding paper award at the Embodied World Models for Decision Making Workshop. As one of fifty accepted papers, our work received great acknowledgment from the community.Our workshop at the 2025 International Conference on Humanoid Robots concluded with great success.
Together with Julian Eßer, Gabe Margolis, and Huazhe Xu, I had the privilege of organizing the Sim-to-Real Transfer for Humanoid Robots Workshop at the 2025 International Conference on Humanoid Robots in Seoul, South Korea. The workshop brought together leading researchers and practitioners to discuss the latest advances and challenges in bridging the gap between simulation and real-world humanoid control.I gave a talk on Learning from Demonstrations at MyoLab.
In this talk, I had the privilege of presenting a comprehensive overview of my experience in the field of Learning from Demonstrations. I discussed the evolution of LfD techniques from feature-based methods to modern generative approaches such as GAN-based learning, and highlighted how these methods have shaped current trends in both robotics and character animation.Two papers were accepted to CoRL 2025.Milestone
Our papers Motion Priors Reimagined: Adapting Flat-Terrain Skills for Complex Quadruped Mobility and Constrained Style Learning from Imperfect Demonstrations under Task Optimality were accepted by Conference on Robot Learning (CoRL) 2025. CoRL 2025 will be held in Seoul, South Korea from September 27 to 30, 2025.We published a survey on Learning from Demonstrations.
While learning from demonstrations has become a widely adopted strategy, many practitioners choose methods based on precedent or anecdotal success rather than a systematic understanding of the algorithmic factors driving performance. Drawing on our extensive experience in the field, we developed Feature-Based vs. GAN-Based Imitation: When and Why, a comprehensive survey designed to provide structured guidance and serve as a practical resource for the community.Our work was accepted to ICRA 2025.Milestone
Our work DFM: Deep Fourier Mimic for Expressive Dance Motion Learning was accepted by IEEE International Conference on Robotics and Automation (ICRA) 2025. ICRA 2025 will be held in Atlanta, United States from May 19 to 23, 2025.
2024
Our work was accepted to NeurIPS 2024.Milestone
Our work Dataset and Lessons Learned from the 2024 SaTML LLM Capture-the-Flag Competition was accepted by The Thirty-Eighth Annual Conference on Neural Information Processing Systems (NeurIPS) 2024. NeurIPS 2024 will be held in Vancouver, Canada from Dec 10 to 15, 2024.I received the ETH Medal at my master's graduation ceremony.Milestone
I feel extremely honored to receive the ETH Medal at my master's graduation ceremony at ETH Zurich. The ETH Medal is awarded to students with outstanding master's and doctoral theses. I am deeply grateful and view this as recognition and acknowledgment of my work during my master's studies. I would like to express my sincere gratitude to my advisors Prof. Georg Martius, Prof. Sangbae Kim, and especially Prof. Marco Hutter for their guidance and support.An unforgettable reunion of friends at my master's graduation ceremony.
The graduation ceremony officially concludes my master's studies at ETH Zurich. It was an unforgettable reunion of friends who shared this great journey with me. I am grateful for the opportunity to have met so many wonderful people during my studies. I am excited to see where our paths will lead us next.Our work was accepted to ICLR 2024 Generative Models for Decision Making workshop.
Our work FLD: Fourier Latent Dynamics for Structured Motion Representation and Learning was accepted to the Generative Models for Decision Making (GenAI4DM) workshop at The Twelfth International Conference on Learning Representations (ICLR). This workshop aims to bring together researchers and practitioners from the fields of generative AI and decision making to explore the latest advances, methodologies, and applications.Our defense won second prize in the LLM CTF competition at IEEE SaTML 2024.
Our team won second prize with our Llama-2-70b-chat defense in the Large Language Models Capture-the-Flag (LLM CTF) competition at 2024 IEEE Conference on Secure and Trustworthy Machine Learning (SaTML). In this competition, participants assume the roles of defenders who craft prompts and filters to instruct an LLM to keep a secret, aiming to prevent its discovery in a conversation.Our work was accepted to ICRA 2024.Milestone
Our work Learning Diverse Skills for Local Navigation under Multi-constraint Optimality was accepted by IEEE International Conference on Robotics and Automation (ICRA) 2024. ICRA 2024 will be held in Yokohama, Japan from May 13 to 17, 2024.Our work was accepted to ICLR 2024 for a spotlight presentation.Milestone
Our work FLD: Fourier Latent Dynamics for Structured Motion Representation and Learning was accepted by The Twelfth International Conference on Learning Representations (ICLR) for a spotlight presentation. ICLR 2024 will be held in Vienna, Austria from May 7 to 11, 2024.
2023
I started my Ph.D. journey as a doctoral fellow at ETH AI Center.
I am excited to share that I started my Ph.D. program as a doctoral fellow at ETH AI Center at ETH Zurich, Switzerland. I am honored to be co-supervised by Prof. Andreas Krause and Prof. Marco Hutter.I finished my visit at the Biomimetic Robotics Lab at MIT.
I am thrilled to wrap up my visit with the talented team at the Biomimetic Robotics Lab at Massachusetts Institute of Technology (MIT), Cambridge, United States. It has been an invaluable experience, collaborating on cutting-edge legged robotics. I am eager to see our collective efforts make a meaningful impact on the robot learning community!Great time at ICRA 2023.
It was wonderful to have met my old and new friends during IEEE International Conference on Robotics and Automation (ICRA) 2023 in London, United Kingdom. I am excited to see that our work Versatile Skill Control via Self-supervised Adversarial Imitation of Unlabeled Mixed Motions has been acknowledged by the greatest roboticists in the field. Thanks to the team Sebastian Blaes, Pavel Kolev, Marin Vlastelica, Jonas Frey and Georg Martius, who made this work possible.Our work was accepted to ICRA 2023 Agile Movements workshop.
Our work Versatile Skill Control via Self-supervised Adversarial Imitation of Unlabeled Mixed Motions was accepted to the Agile Movements: Animal Behavior, Biomechanics, and Robot Devices workshop at IEEE International Conference on Robotics and Automation (ICRA) 2023. This workshop invites researchers to identify the challenges and opportunities of understanding and improving robotic agility from a diverse range of areas, including biology, biomechanics, mechanism design, and control.I received the ETH AI Center Doctoral Fellowship.Milestone
I am excited to share that I received the ETH AI Center Doctoral Fellowship at ETH Zurich, Switzerland. The ETH AI Center Fellowship is awarded to doctoral students, who are co-supervised by two faculty members from different departments within ETH Zurich, thus fostering a culture of interdisciplinary exchange and collaboration. I am extremely honored to receive this offer from Prof. Andreas Krause and Prof. Marco Hutter.Our work on Solo robots at MPI-IS was reported by a German TV network.
My work on Solo robots during my internship at the Max Planck Institute for Intelligent Systems was covered in NANO on 3sat. In the coverage, Prof. Georg Martius explained how autonomous learning systems can obtain extraordinary intelligence from interactions with the environment.I received admission offers to the Ph.D. programs at MIT EECS and other prominent institutes.Milestone
I am excited to share that I received admission offers to the Ph.D. programs at the departments of Electrical Engineering and Computer Science (EECS) and Mechanical Engineering (MechE) at Massachusetts Institute of Technology (MIT), Cambridge, United States. I was also lucky to be admitted to the Robotics Institute at Carnegie Mellon University (CMU), Pittsburgh, United States. I am honored and view these as recognition and acknowledgment of my work during my master's studies.Our work was accepted to ICRA 2023.Milestone
Our work Versatile Skill Control via Self-supervised Adversarial Imitation of Unlabeled Mixed Motions was accepted by IEEE International Conference on Robotics and Automation (ICRA). ICRA 2023 will be held in London, United Kingdom from May 29 to June 2, 2023.I started my visit at Biomimetic Robotics Lab at MIT.
Starting from January, I am honored to work with Prof. Sangbae Kim at Biomimetic Robotics Lab at Massachusetts Institute of Technology (MIT), Cambridge, United States. My main research topic focuses on developing latent skill representation for the MIT Humanoid robot. I am happy to collaborate with Steve Heim and Elijah Stanger-Jones on this exciting topic.
2022
Great time at CoRL 2022 and satisfying results for my first publication.
It was wonderful to have met all the great names and my future collaborators and advisors during Conference on Robot Learning (CoRL) 2022 in Auckland, New Zealand. I am excited to see that our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations has been acknowledged by the greatest roboticists in the field and was named a finalist for the Best Paper Award. Thanks to the team Marin Vlastelica, Sebastian Blaes, Jonas Frey, Felix Grimminger and Georg Martius, who made this achievement possible.Our work was named a finalist for the Best Paper Award at CoRL 2022, Auckland, New Zealand.Milestone
It was announced during Conference on Robot Learning (CoRL) 2022 in Auckland, New Zealand that our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was named a finalist for the Best Paper Award. As one of the three nominated papers, our work received great acknowledgment from the community.Our work was presented to the Machines in Motion Laboratory, New York University, United States.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was presented to the scholars at the Machines in Motion Laboratory led by Prof. Ludovic Righetti at New York University. The Machines in Motion Laboratory focuses on understanding the fundamental principles for robot locomotion and manipulation that will endow robots with the robustness and adaptability necessary to efficiently and autonomously act in an unknown and changing environment.I will join the Biomimetic Robotics Lab at MIT for my master thesis.
I am glad to share that I will join the Biomimetic Robotics Lab led by Prof. Sangbae Kim at Massachusetts Institute of Technology (MIT) to complete my master thesis later this year. The Biomimetic Robotics Lab focuses on designing and controlling robots using insights taken from the natural world. I will be working with the MIT Humanoid on human demonstration imitation.Our work was accepted to CoRL 2022 Learning for Agile Robotics workshop.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was accepted to the Learning for Agile Robotics workshop at Conference on Robot Learning (CoRL) 2022. This workshop invites researchers working on making agile robots. The goals include fostering collaboration, understanding the current limitations and inefficiencies, learning common ideas on modern ML based approaches, etc.Our work made it into the Video Friday collection at IEEE Spectrum again.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was covered by Video Friday collection at IEEE Spectrum. Video Friday is a weekly selection of state-of-the-art robotics videos, collected by scholars at IEEE Spectrum Robotics. This time, our overview video was selected and well acknowledged.Our work was submitted to IEEE International Conference on Robotics and Automation (ICRA) 2023.
During the second three months of my internship, I accomplished the work Versatile Skill Control via Self-supervised Adversarial Imitation of Unlabeled Mixed Motions under the guidance of Sebastian Blaes, Pavel Kolev, Marin Vlastelica, Jonas Frey and Prof. Georg Martius. In this work, Solo obtained diverse skills by imitating unlabeled, mixed reference motions.Our work was accepted to CoRL 2022 for an oral presentation with a Best Paper Award nomination.Milestone
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was accepted by Conference on Robot Learning (CoRL) 2022 for an oral presentation with a Best Paper Award nomination. CoRL 2022 will be held in Auckland, New Zealand from December 14 to 18, 2022.Our work was presented to the Robotic Systems Lab, ETH Zurich, Switzerland.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was presented to the scholars at the Robotic Systems Lab (RSL), ETH Zurich during the research presentation. In this weekly event, internal and external researchers are invited to present their state-of-the-art discoveries in fields including robotic system integration and control methods.Our work was presented to the public at the Science & Innovation Days, Tübingen.
The experiments of our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations were presented to the public at the Tübingen Science & Innovation Days. In this event, research institutes including the Max Planck Institute for Intelligent Systems open their doors to the interested public and present their research.Our work made it into the Video Friday collection at IEEE Spectrum.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was covered by Video Friday collection at IEEE Spectrum. Video Friday is a weekly selection of state-of-the-art robotics videos, collected by scholars at IEEE Spectrum Robotics. Among our selected videos, SOLOBACKFLIP gained particular popularity.Our work was presented to scholars from the International Max Planck Research School for Intelligent Systems.
Our work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations was presented to the evaluation committee and Ph.D. scholars from the International Max Planck Research School for Intelligent Systems (IMPRS) during the on-site evaluation.Our work was submitted to Conference on Robot Learning (CoRL) 2022.
During the first three months of my internship, I accomplished the work Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations under the guidance of Marin Vlastelica, Sebastian Blaes, Jonas Frey, Felix Grimminger and Prof. Georg Martius. In this work, Solo developed highly dynamic skills by imitating rough, partial, human-demonstrated reference motions.I started my internship at Autonomous Learning Group at Max Planck Institute for Intelligent Systems.
Starting from April, I am honored to work with Prof. Georg Martius at Autonomous Learning Group at Max Planck Institute for Intelligent Systems (MPI-IS), Tübingen, Germany. My main research topic focuses on agile skill development and style diversification for Solo robot. This work is closely collaborated with Robotic Systems Lab (RSL), ETH Zurich, Switzerland.My semester project at Robotic Systems Lab (RSL) finished with successful policy deployment on the real system.
By employing a novel compositional control structure, ANYmal learned to achieve full-pose trajectory tracking in a global coordinate system. A hierarchical system pipeline was introduced, where the high-level policy processes global target information and outputs low-level composition signals and commands with trivial regularization.
2021
I started my semester project at Robotic Systems Lab (RSL), ETH Zurich, Switzerland.
From October, I am honored to work on a semester project on the skill integration for ANYmal with hierarchical reinforcement learning at Robotic Systems Lab (RSL) directed by Prof. Marco Hutter. The main research topic focuses on extending locomotion and manipulation capabilities for legged systems by leveraging appropriate combination of acquired skills. This project is mainly supervised by Yuntao Ma, Takahiro Miki and Mayank Mittal.I started my teaching assistant position for Linear & Combinatorial Optimization at ETH Zurich, Switzerland.
After having achieved top grades in the course Linear & Combinatorial Optimization (L&CO, 11 ECTS) instructed by Prof. Rico Zenklusen at ETH Zurich last semester, I was honored to take a teaching assistant position for the new semester. Among my responsibilities, I enjoyed delivering lectures the most.Wonderful week at ETH Robotics Summer School in Wangen an der Aare, Switzerland.
From July 2 to 9, I was honored to participate in the ETH Robotics Summer School directed by ETH RobotX initiative. During this event, a broad scope of components of autonomous mobile robots including state estimation, trajectory optimization, environment mapping, path planning, and artifact detection were introduced and implemented on a wheeled platform, SuperMegaBot. On the last day, we successfully completed an autonomous rescue challenge at the test site.
2020
I started my master's program in Robotics, Systems and Control at ETH Zurich, Switzerland.
After receiving offers from top-class universities including University of California, Los Angeles (UCLA), Johns Hopkins University (JHU), École polytechnique fédérale de Lausanne (EPFL), Imperial College London, etc, I decided to pursue my future endeavors in Robotics, Systems and Control under the guidance of Prof. Marco Hutter at ETH Zurich, Switzerland.I was awarded Excellent Graduate of Shanghai.
Together with 11 other students from the School of Mechanical Engineering, it was my honor to be granted the highest honor for all undergraduates of all majors from more than ten universities in Shanghai this year.My research project at Biorobotics Laboratory (BioRob) finished with successful hardware test.
My work on Analysis, Design and Implementation of a Bio-inspired Passive Tail for Amphibious Robots concluded with a novel development of an appropriate chordwise stiffness distribution along a bio-inspired tail for AgnathaX which maximizes the propulsion generated under a combined movement of both passive heaving and pitching.
2019
I started my research project at Biorobotics Laboratory (BioRob) at École polytechnique fédérale de Lausanne (EPFL), Switzerland.
I am honored to work as a research assistant on the design of a bio-inspired passive tail for amphibious robots at Biorobotics Laboratory (BioRob) directed by Prof. Auke Ijspeert during the last year of my bachelor's study. This project is mainly supervised by Laura Paez.
2018
I was awarded my second National Scholarship for my study at Tongji University, Shanghai, China.
The Ministry of Education of China funded the China National Scholarship to award outstanding full-time undergraduates for their excellent academic records. Being among the top 1% of the students of the same year again, I am honored to receive this award a second time.I finished my research internship at Advanced Multifunctional and Multiphysics Metamaterials Lab (AM3L) of the Department of Bioresource Engineering of McGill University, Montréal, Canada.
From July to October, I was honored to be selected for the Mitacs Globalink Research Internship program and to work on Design and 3D Printing of Lightweight Advanced Energy Harvesters Made of Smart Materials under the supervision of Prof. Abdolhamid Akbarzadeh. The research was devoted to reinforcing mechanical properties of 3D printing materials by combining pulverized wood particles with melted polymer through a novel process of extrusion.I was awarded Meritorious Winner in 2018 Mathematical Contest in Modeling.
I am honored to receive my first international award in Mathematics.
2016
I was awarded my first National Scholarship for my study at Tongji University, Shanghai, China.
The Ministry of Education of China funded the China National Scholarship to award outstanding full-time undergraduates for their excellent academic records. Being among the top 1% of the students of the same year, I am honored to receive this award.
Featured research.
First-author work on learning agile, natural and general robot behavior, from world models to imitation.
ICLR 2023Spotlight
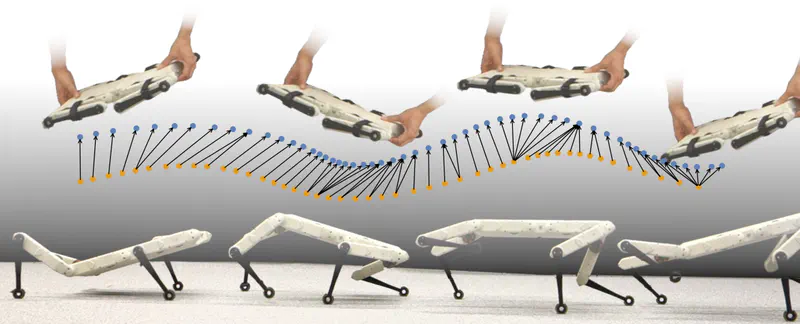
FLD: Fourier Latent Dynamics for Structured Motion Representation and Learning
We propose a self-supervised, structured representation and generation method that extracts spatial-temporal relationships in periodic or quasi-periodic motions.
CoRL 2022Best Paper Award Finalist
Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations
We propose a generative adversarial method for inferring reward functions from partial and potentially physically incompatible demonstrations for successful skill acquisition where reference or expert demonstrations are not easily accessible.
All publications.
Google Scholar2026
Watch Your Step: Anticipated Perception for Humanoid Locomotion
PetriBench: Benchmarking LLM Reasoning over Dynamic State Spaces
ADAPT: Agile Diffusion Action Priors for Robust and Steerable Online Text-Driven Humanoid Control
Enhancing VLM Reward Models Through Structure-Aware Fine-Tuning
EgoHTR: Egocentric 4D Demonstrations of Human Terrain Traversal
Bridging the Gap: Enabling Soft Actor Critic for High Performance Legged Locomotion
Learning Whole-Body Humanoid Locomotion via Motion Generation and Motion Tracking
PAINT: Partner-Agnostic Intent-Aware Cooperative Transport with Legged Robots
Morphology-Conditioned World Model for Cross-Embodiment Quadrupedal Locomotion
Model-Based Reinforcement Learning for Control under Time-Varying Dynamics
What Matters for Simulation to Online Reinforcement Learning on Real Robots
NIL: No-data Imitation Learning
Scaling Rough Terrain Locomotion with Automatic Curriculum Reinforcement Learning
Multi-Domain Motion Embedding: Expressive Real-Time Mimicry for Legged Robots
Uncertainty-Aware Robotic World Model Makes Offline Model-Based Reinforcement Learning Work on Real Robots
2025
Robotic World Model: A Neural Network Simulator for Robust Policy Optimization in Robotics
Learning Soft Robotic Dynamics with Active Exploration
Constrained Style Learning from Imperfect Demonstrations under Task Optimality
Feature-Based vs. GAN-Based Learning from Demonstrations: When and Why
Motion Priors Reimagined: Adapting Flat-Terrain Skills for Complex Quadruped Mobility
Symmetry-Guided Memory Augmentation for Efficient Locomotion Learning
DFM: Deep Fourier Mimic for Expressive Dance Motion Learning
Learning More With Less: Sample Efficient Dynamics Learning and Model-Based RL for Loco-Manipulation
2024
Experience.
Labs and teams I’ve had the privilege to learn from.
Work

Jan 2023 – Aug 2023
Visiting Researcher
Massachusetts Institute of Technology
Human motion representation and developmental robotics with Prof. Sangbae Kim.
Apr 2022 – Dec 2022
Research Intern
Max Planck Institute for Intelligent Systems
Agile motion imitation and intrinsic skill exploration with Prof. Georg Martius.
Sep 2019 – Jan 2020
Research Assistant
École polytechnique fédérale de Lausanne (EPFL)
Analysis, design and implementation of a bio-inspired passive tail for amphibious robots with Prof. Auke Ijspeert.
Education
Nov 2023 – Present
PhD in Artificial Intelligence
ETH AI Center

Sep 2015 – Jun 2020
BSc in Mechanical Engineering
Tongji University
GPA: 4.92/5.0
National Scholarship Winner, ranking first in the department for five consecutive years.
Writing.
Longer reads on the ideas behind the research.
July 2025 · 23 min read
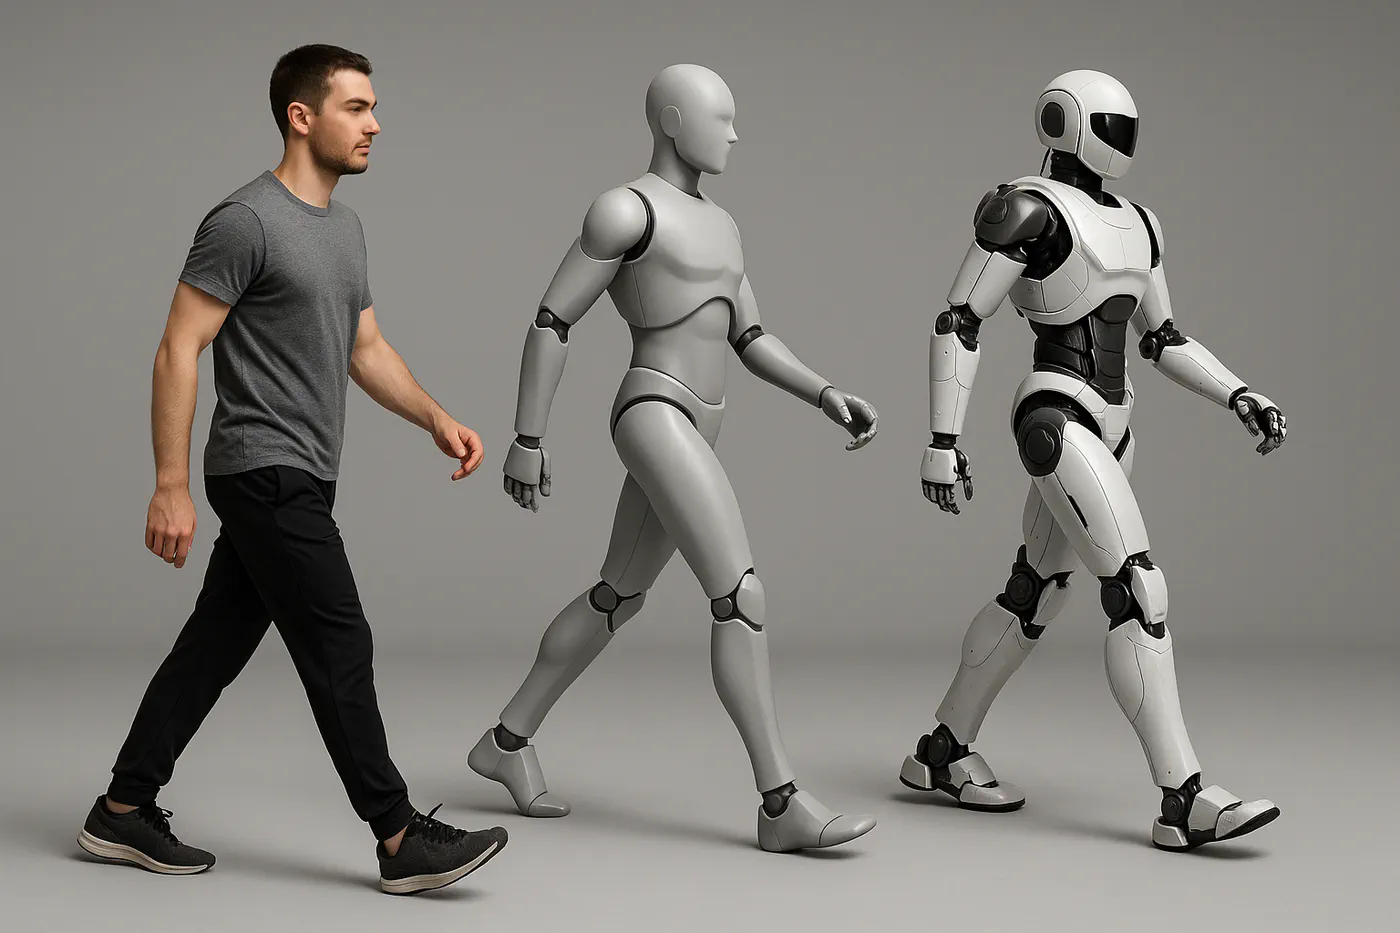
Feature-Based vs. GAN-Based Imitation: When and Why
Comparing feature-based and GAN-based methods for learning from demonstrations shows that the key to success lies less in the method itself and more in the structure and suitability of the motion representation for the task.
Talks.
Invited presentations at labs and companies around the world.
April 22, 2026
Robotic World Model: Toward Real-World Online Reinforcement Learning
ARCAD Lab, University of Michigan
January 21, 2025
Developmental Legged Intelligence: from Imitation to Generation
JSK Lab, University of Tokyo
January 20, 2025
Developmental Legged Intelligence: from Imitation to Generation
Sony AI
March 27, 2024
FLD: Fourier Latent Dynamics for Structured Motion Representation and Learning
Toyota Research Institute
March 21, 2024
Journal Club on Pose Estimation and Action Recognition
Shirley Ryan AbilityLab, Northwestern University
March 20, 2024
Leveraging Spatial-Temporal Structures in Self-supervised Motion Representation and Learning
The Robotics Institute, Carnegie Mellon University
March 5, 2024
Developmental Legged Intelligence: from Imitation to Generation
AI4CE Lab, New York University
November 15, 2023
Learning from Limited Demonstrations: Lessons We Have Learned
Learning & Adaptive Systems Group, ETH Zurich
January 12, 2023
Reducing Human Efforts in Reinforcement Learning for Legged Skill Development
Biomimetic Robotics Lab, Massachusetts Institute of Technology
December 2, 2022
Reducing Human Efforts for Expert Acquisition in Imitation Learning
Machines in Motion Laboratory, New York University
August 10, 2022
Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations
Robotic Systems Lab, ETH Zurich
Robotic platforms.
The robots I learned and grew up with.
Since 2026
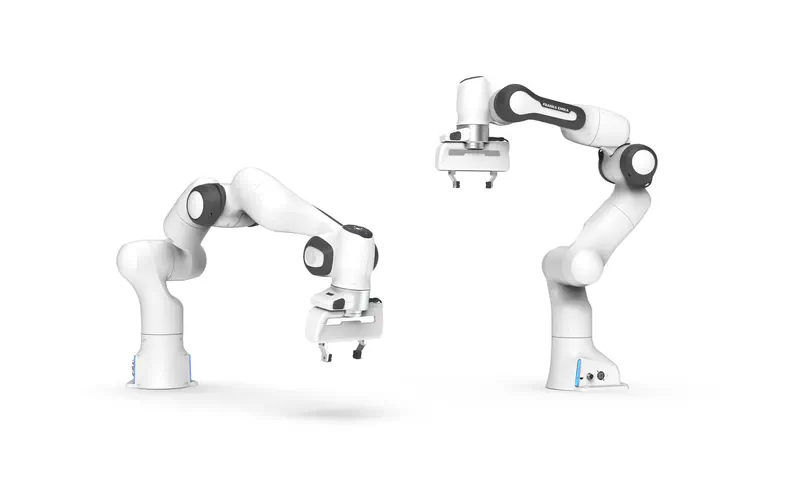
Franka Panda
Franka Panda is a versatile robotic arm designed for manipulation tasks.
Since 2026
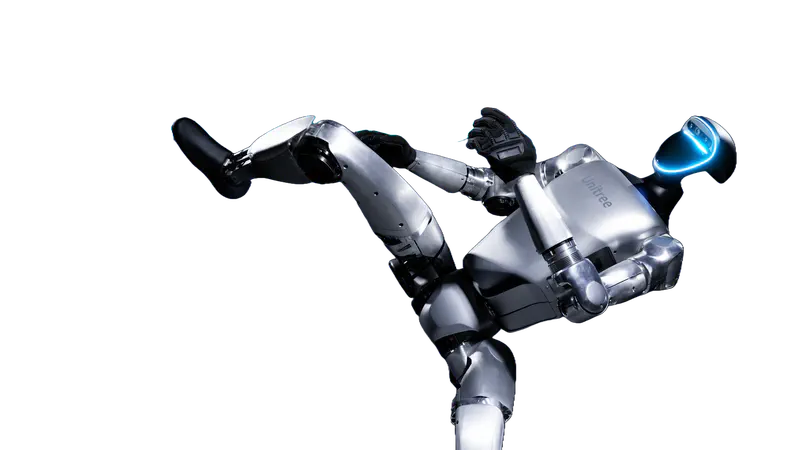
Unitree G1
Unitree G1 features advanced mobility, dexterity, and perception capabilities.
Since 2025
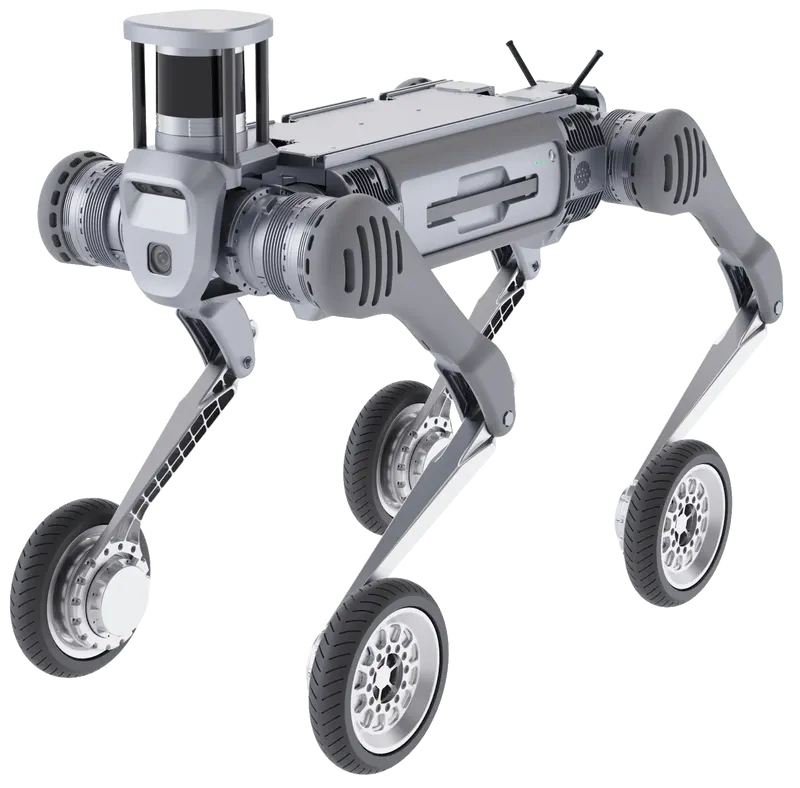
Unitree B2-W
Unitree B2-W combines perceptual and motor control to maintain balance and cope with a variety of discrete terrains.
Since 2025
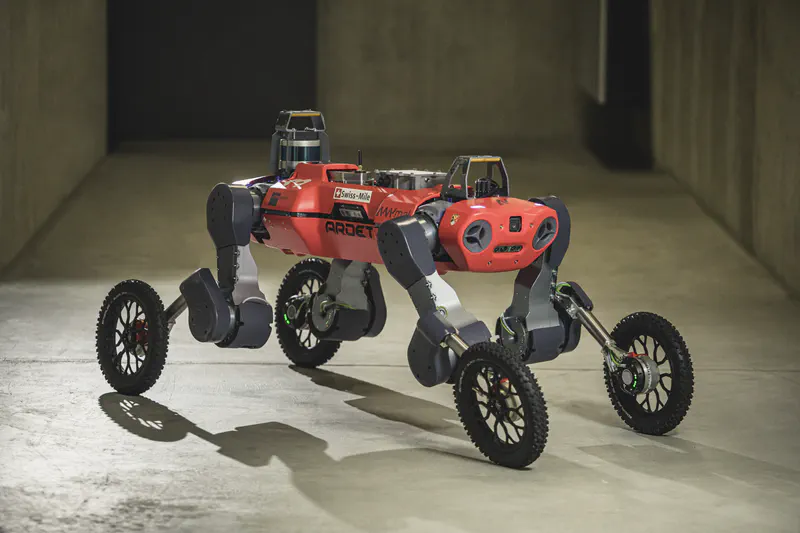
ANYmal on Wheels
ANYmal on Wheels is equipped with non-steerable, torque-controlled wheels to overcome the trade-off between mobility and efficiency.
Since 2024
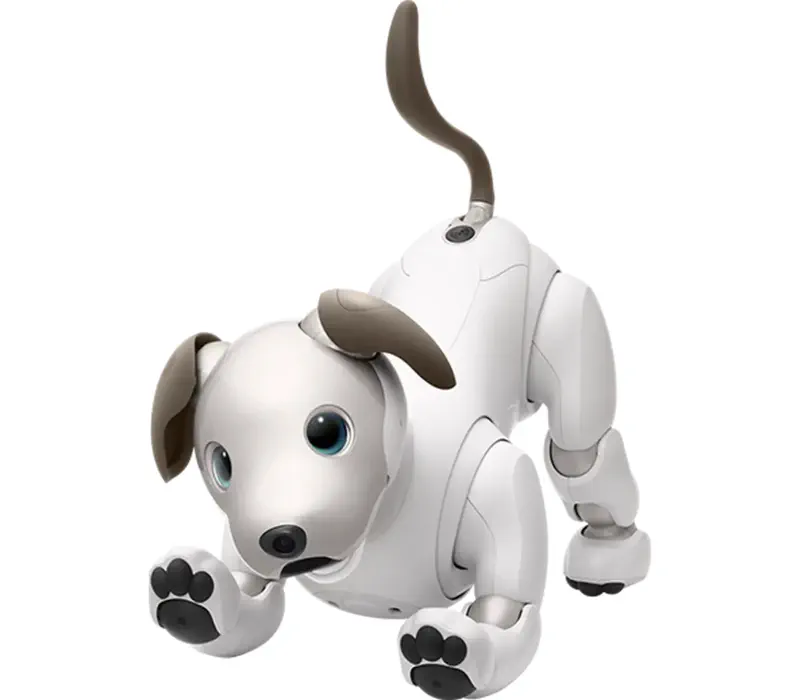
Sony aibo
Sony aibo grows each day and acquires an identity depending on its living environment and relationship with people.
Since 2023
MIT Humanoid
MIT Humanoid is built for highly dynamic skills over challenging terrains.
Since 2023
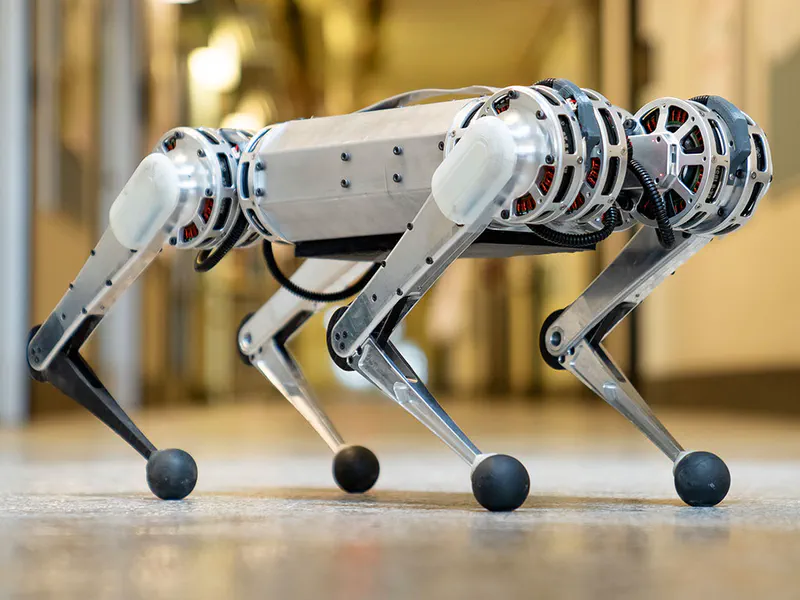
Mini Cheetah
Mini Cheetah is a lightweight, high-power quadruped robot designed for extraordinarily agile motions.
Since 2022
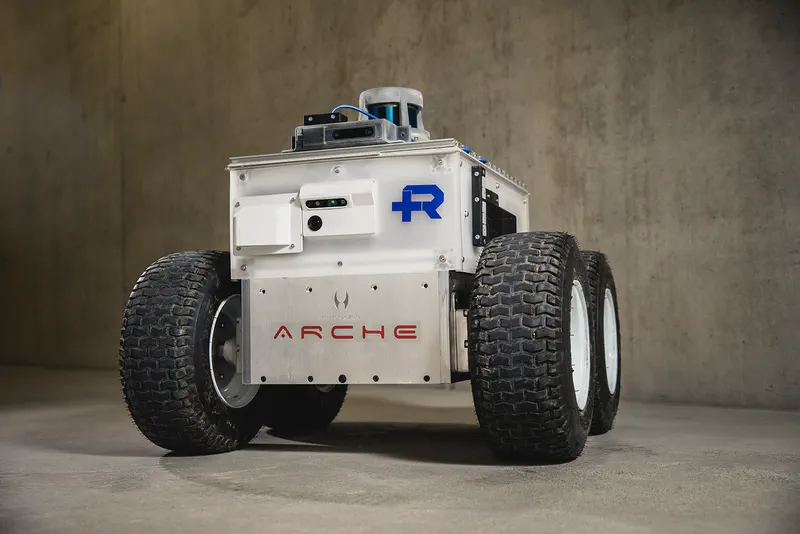
SuperMegaBot
SuperMegaBot is a 4-wheeled mobile robot for autonomous site inspection and artifact detection.
Since 2022
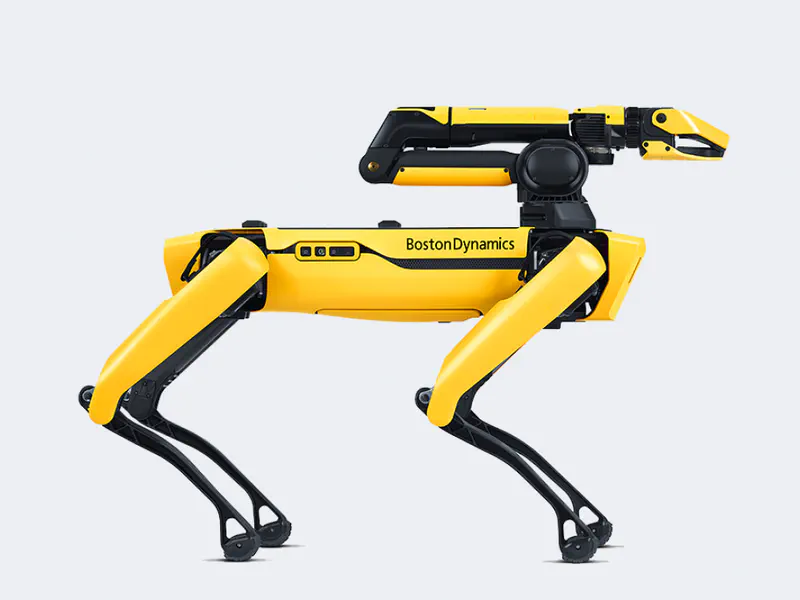
Spot
Spot is an agile mobile robot that navigates complex terrains for automated routine inspection and data capture.
Since 2022
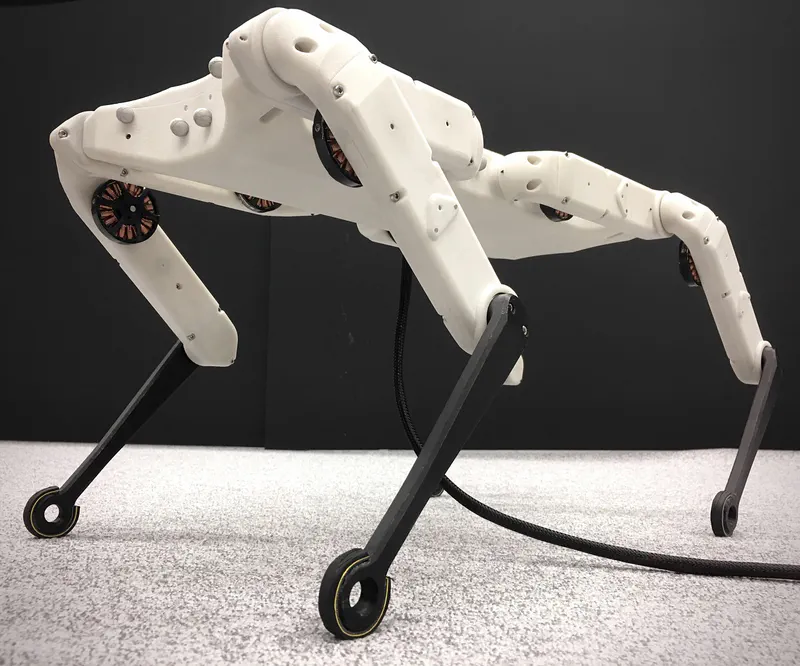
Solo
Solo is an open-source lightweight research quadruped robot that allows highly dynamic actuation.
Since 2022
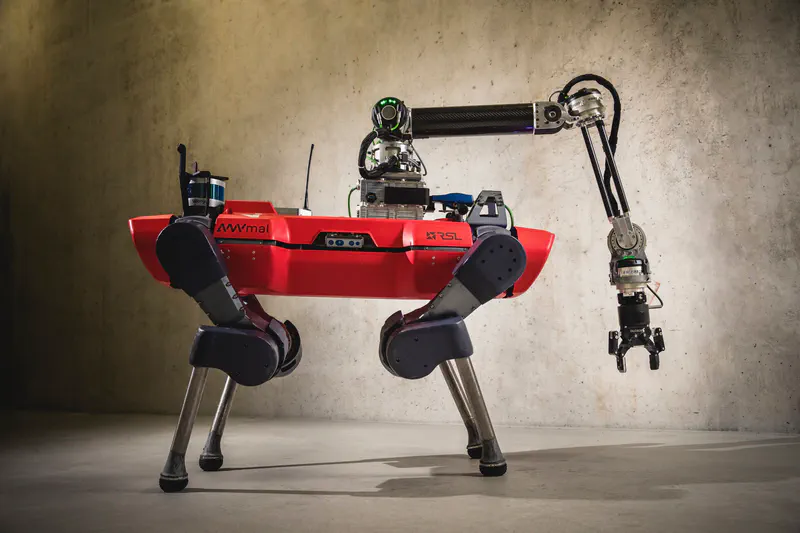
ALMA
ALMA is equipped with a robotic arm designed for articulated locomotion and manipulation.
Since 2021
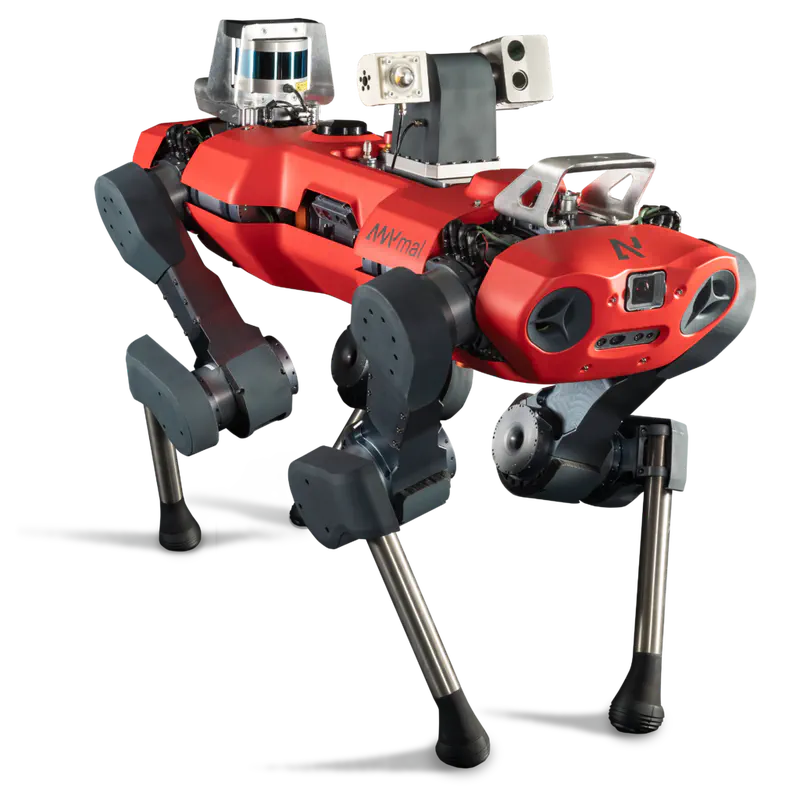
ANYmal
ANYmal is optimized for automated industrial inspection tasks with a wide range of sensors.
Since 2019
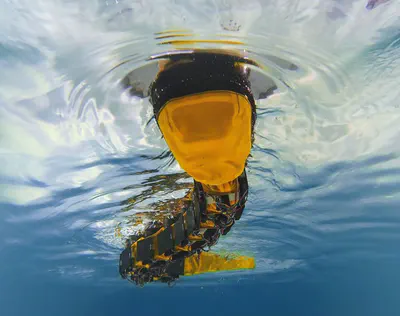
AgnathaX
AgnathaX is an undulatory swimming robot equipped with distributed force sensors to study the neural mechanisms controlling locomotion in the spinal cord.